QNX-Based Real-Time Control for EAST Poloidal Field Power Supply Site Layer
This paper presents the design and implementation of the site-level real-time control layer for the EAST tokamak poloidal field (PF) power supply system. Utilizing QNX 6.3.2 and Ethernet fieldbus modules with Modbus/UDP, the system achieves a deterministic 4 ms control cycle, enabling precise distributed control of 12 independent power supply units.
🔧 System Overview #
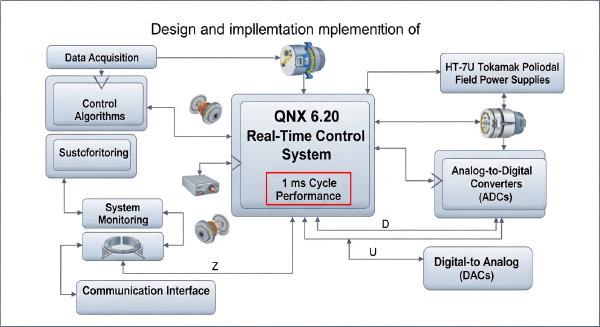
The EAST PF system is composed of 12 distributed power supply units, each managing transformers, thyristor converters, switches, and protection circuits. The site-level control layer integrates:
- QNX-based control nodes for each PF unit.
- Ethernet fieldbus controllers (WAGO) for I/O acquisition and control.
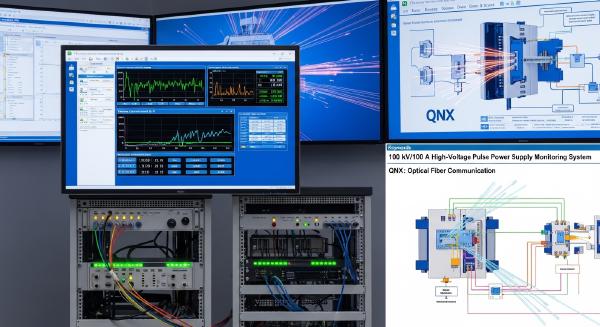
- Optical fiber communication for high-voltage isolation.
- Deterministic real-time cycle: 4 ms validated under full load.
The architecture ensures safe, reliable, and responsive control during plasma initiation, shaping, and sustainment.
🏗 System Architecture #
Platform Selection #
QNX 6.3.2 was selected for its superior real-time performance:
| Performance | QNX 6.3.2 | VxWorks AE1.1 | Windows CE .NET | ELDS 1.1 |
|---|---|---|---|---|
| Interrupt Latency (max/avg) | 4.3 / 1.7 µs | 6.8 / 1.7 µs | 5.6 / 2.4 µs | 4.0 / 3.2 µs |
| Thread Switch Time | 21.8 / 8.8 µs | 46.8 / 6.8 µs | 16.7 / 9.6 µs | N/A |
| Min Interrupt Period | 9 µs | 25 µs | 11 µs | 60 µs |
| Lightweight Cross-Network IPC | Yes (Qnet) | No | No | No |
| Scheduling | FIFO, RR, Adaptive | Priority, RR | RR | FIFO, RR |
QNX’s microkernel and Qnet message-passing make it ideal for distributed hard real-time control.
Fieldbus Communication #
- Modules: WAGO Ethernet fieldbus using Modbus/TCP.
- Protocol: High-speed Modbus/UDP for deterministic messaging.
- Cycle Time: 4 ms for all critical control loops.
- Tested under load with no packet loss.
Network Topology #
- 12 QNX Power Control Nodes connected via Ethernet switches.
- Optical fiber links provide high-voltage isolation.
- Redundant switches deployed for fault tolerance.
⚙️ Software Design of Power Control Nodes #
Each node runs a dedicated QNX project controlling one PF unit.
Processes and Functions:
- Fieldbus operation threads for real-time communication.
- Board card DA/DIO control for ultra-fast I/O.
- Initialization, polling, thyristor firing, and circulating current control.
- Switch control: fast DC and charging switches.
- Status monitoring, fault detection, and reporting to upper layers.
Communication with upper QNX layers is achieved via reflective memory or network messages.
📊 Testing and Validation #
- First plasma discharge confirmed real-time operation.
- Key parameters (pulse blocking, busbar temperature, water pressure, alarms) reliably monitored.
- Switches controlled accurately with fast fault detection.
- 4 ms control cycle maintained under full load, demonstrating stability and determinism.
🏁 Conclusion #
The QNX-based site-level real-time control layer successfully delivers:
- Distributed hard real-time control of 12 PF power supply units.
- Deterministic 4 ms control cycle.
- High stability, reliability, and fault tolerance.
- Safe integration with fieldbus layer using Modbus/UDP and optical isolation.
🔮 Modern Perspective (2026) #
Enhancements could include:
- QNX SDP 8.x / Helix for multi-core real-time scheduling.
- TSN or EtherCAT for sub-millisecond deterministic control.
- Integration with OPC UA or DDS for improved interoperability and remote monitoring.
- Safety-certified profiles for next-generation tokamak PF control systems.